Standard series
FR3
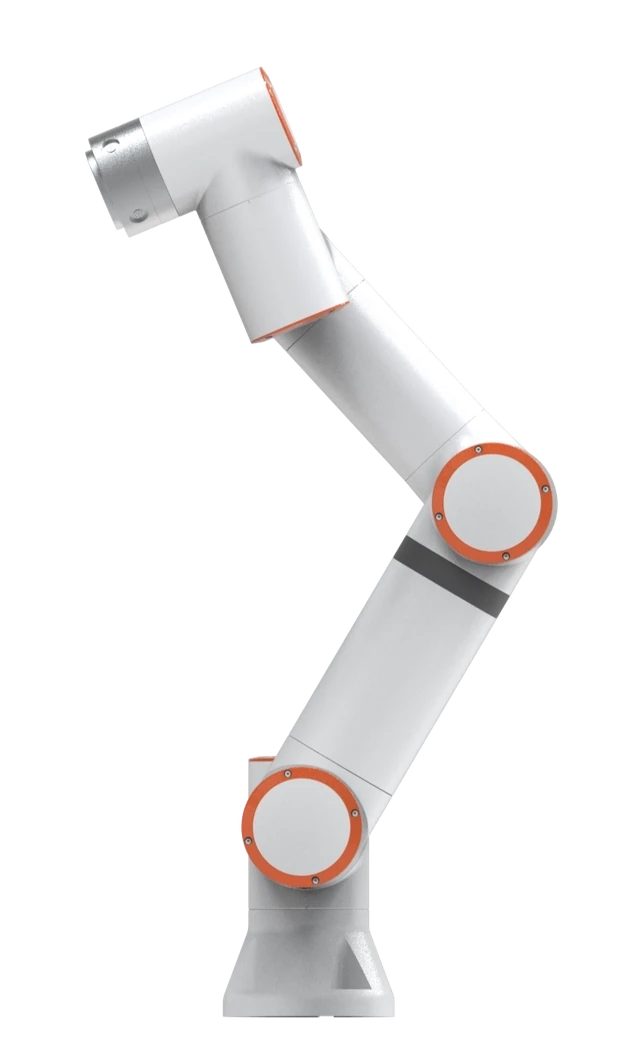
Payload3 kg
Reach622 mm
A compact 3 kg arm for precise handling and tight workspaces.
Explore FR3Define how parts arrive, how they can be gripped, and what a successful handoff looks like.
Are parts located, randomly oriented, moving on a conveyor, or mixed in a container? Show the range of incoming conditions.
Identify usable contact surfaces, allowed clamping force, part sensitivity, and the space available for the tool.
Specify the receiving position, orientation, tolerance, and signals needed before the robot releases the part.
Plan how the process checks that a part was acquired and placed, and what happens when either check fails.
Bring your part, process, and production goals. Get practical guidance on robot selection and the complete application.
Request a consultationExplore these configurations, then review the tooling, layout, and complete cell requirements for your process.
A compact 3 kg arm for precise handling and tight workspaces.
Explore FR3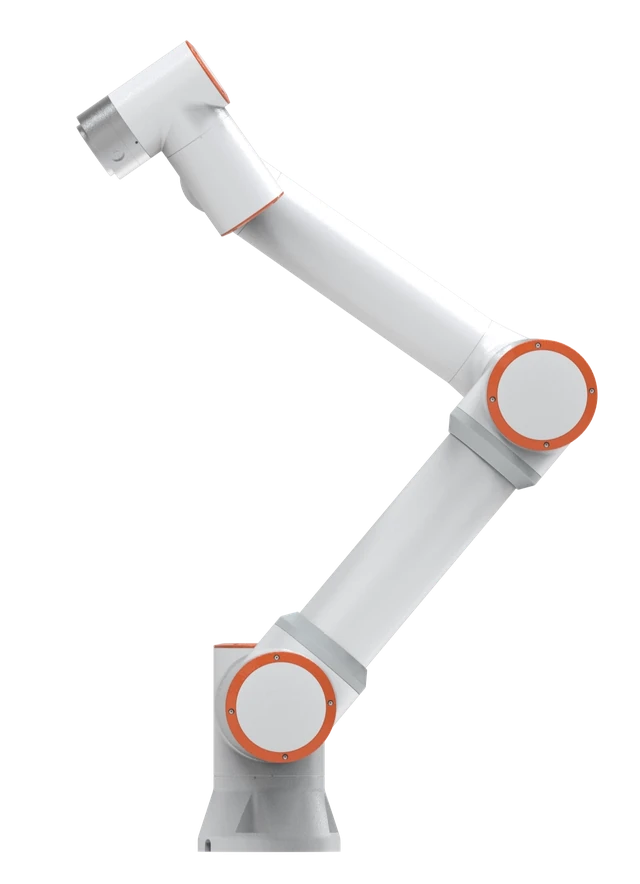
A versatile 5 kg arm with 922 mm reach for everyday automation.
Explore FR5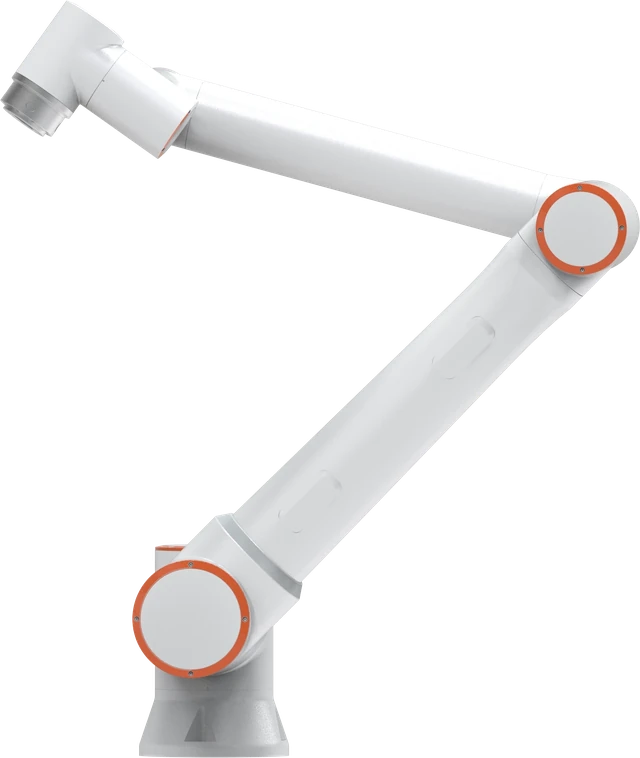
A 10 kg arm with 1,400 mm reach for a larger working envelope.
Explore FR10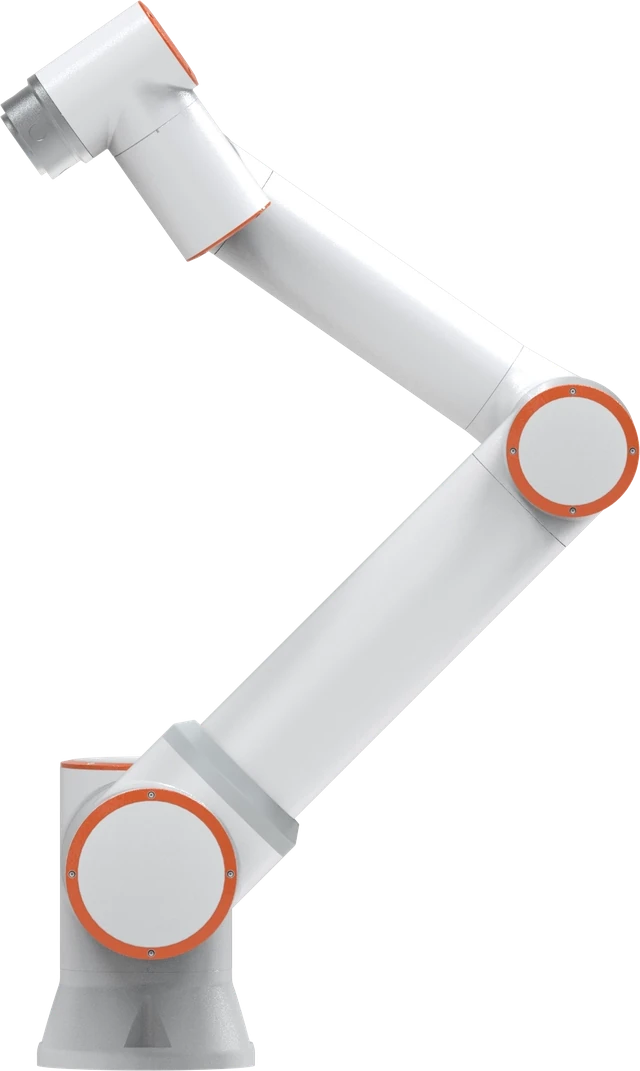
A 16 kg payload in a 1,034 mm working envelope.
Explore FR16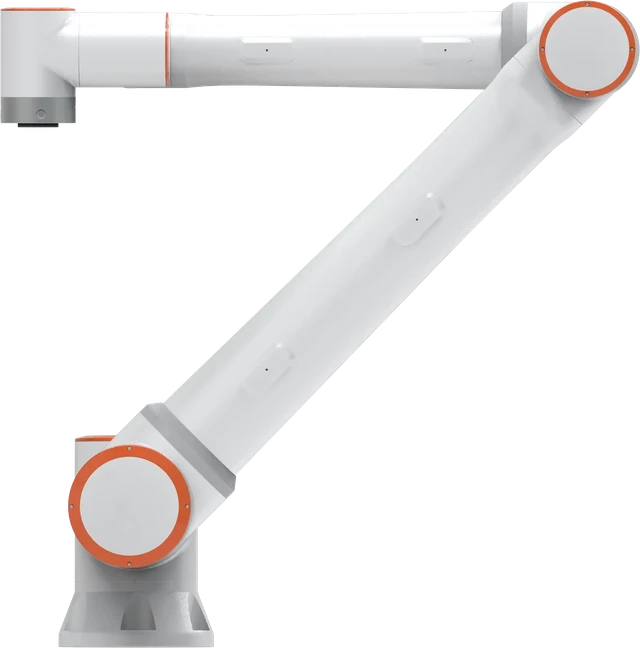
A 20 kg arm with 1,854 mm reach for larger parts and layouts.
Explore FR20Explore the full lineup or request a consultation to select a configuration for your process.
Have an application in mind? Start with a conversation about the parts, the process, and what a useful solution needs to do.
Use these guides to describe your process and prepare the questions you want to discuss.
Request a demo or consultation| Scope | Define before comparing prices |
|---|---|
| Part presentation | Trays, fixtures, conveyors or bins, including the actual part variation. |
| Robot and end effector | Robot configuration, carried tool mass, grip verification and placement access. |
| Vision and controls | Camera, lighting, calibration and interfaces only where the variability requires them. |
| Acceptance | Sustained accepted placements, product changeover, missed picks and recovery. |
A structured tray-handling cell and a vision-guided bin-picking cell are different purchases. Ask for separate robot, tooling, sensing and integration lines, then compare the cost per accepted placement under your real part mix.
Specify the vision and handling requirements, then discuss your automation project and the next step toward a demo or proposal.